Presented research at IEEE RO-MAN 2026 in Kitakyushu, Japan, on safe and efficient navigation around texting pedestrians.
Shunya Tadano 只野 竣也
PhD Student, Department of Robotics
Graduate School of Engineering, Tohoku University
shunya.tadano[at]gmail.com
Sydney, Australia
News
Attended Robotics: Science and Systems 2026 (RSS 2026), held from 13–17 July at UTS and ICC Sydney.
A paper was accepted to IEEE RO-MAN 2026 and will be presented in Kitakyushu, Japan.
A new interview article about Kisui's agricultural support robot “Adam” was published in the Journal of the Robotics Society of Japan.
Started a joint overseas research visit at the University of Technology Sydney (UTS) in Sydney, Australia.
Received an Outstanding Presentation Award at SI2025 for work on dynamic costmap adjustment for smartphone-distracted pedestrians.
Presented research at RSJ2025 on 3D-skeleton-based detection of distracted pedestrians for autonomous mobile robots.
Visited the Takahashi Laboratory at Keio University to exchange ideas across robotics and human-centered systems.
Presented a poster at ROBOMECH2025 on collision avoidance using attention-aware costmap generation.
An interview article with Living Robot Inc. about the future of walking robots through “MechatroWeGo” was published.
Publications
Conference presentations and editorial work. For the latest record and presentation materials, visit researchmap ↗ or Docswell ↗.
International Presentation
02 items-
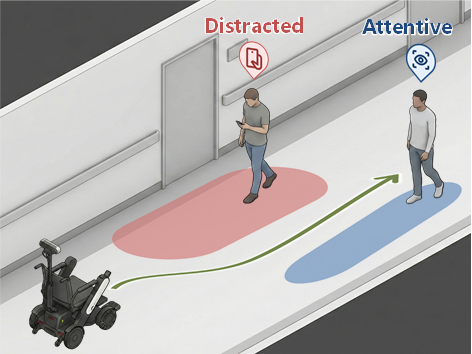
Safe and Efficient Navigation Considering Texting Pedestrians via Attention-Aware Cost-map Tuning
Shunya Tadano, Yusuke Tamura, A. A. Ravankar, and Yasuhisa Hirata
2026 IEEE International Conference on Robot and Human Interactive Communication (RO-MAN), Kitakyushu, Japan, Paper ID: WeD04.4.
-
Pedestrian Trajectory Prediction with Pose Estimation and Monte Carlo Dropout
Shunya Tadano, Yusuke Tamura, and Yasuhisa Hirata
2024 IEEE International Conference on Robotics and Automation, ThAL-EX.17.
Domestic Presentations
06 items-
Dynamic Costmap Adjustment for Autonomous Mobile Robots Considering Smartphone-Distracted Pedestrians
歩きスマホ歩行者の注意状態を考慮した自律移動ロボットの動的なコストマップ調整
Shunya Tadano, Yusuke Tamura, and Yasuhisa Hirata
26th SICE System Integration Division Conference, presentation 1E3-09.
-
Detecting Distracted Pedestrians Using 3D Skeletal Information for Autonomous Mobile Robots
自律移動ロボットのための3D骨格情報に基づく歩きスマホ検出
Shunya Tadano, Yusuke Tamura, and Yasuhisa Hirata
43rd Annual Conference of the Robotics Society of Japan, 3J3-03.
-
Collision Avoidance for Mobile Robots with Attention-Aware Cost Map Generation
歩行者の注意状態を考慮したコストマップ生成による移動ロボットの衝突回避
Shunya Tadano, Yusuke Tamura, and Yasuhisa Hirata
Robotics and Mechatronics Conference 2025, 2P1-E05.
-
Integrating Pose Information into Pedestrian Trajectory Prediction Considering Uncertainty
不確実性を考慮した歩行者軌道予測への姿勢情報の統合
Shunya Tadano, Yusuke Tamura, and Yasuhisa Hirata
Robotics and Mechatronics Conference 2024, 2P2-N01.
-
Development of an Autonomous Mobile Robot for Arctic Sea-Ice Surveys
北極海氷調査自律移動ロボットの開発―氷雪上走行における検討と高精度測位システムの基礎的開発―
米倉 達郎, 古舘 守道, 只野 竣也, 菅 良太郎, 吉田 弘, 三好 扶
Robotics and Mechatronics Conference 2022, 1A1-L03.
-
Development of an Underwater Antenna and Its Application to Polar Exploration Robots
海中アンテナの開発とその極域探査ロボットへの応用
吉田 弘, 野一色 崇志, 高橋 応明, 屋比久 怜, 菅 良太郎, 米倉 達郎, 只野 竣也, 川村 昴, 松下 拓磨, 松井 康浩
IEICE Technical Report, 2022.
Misc
03 items-
Project on Student Editorial Committee: Interview with Kisui Co., Ltd.
宇宙探査技術で農業課題を解決!輝翠の農作業支援AIロボット「Adam」の開発
Sena Ishii, Shinya Tajima, and Shunya Tadano
Journal of the Robotics Society of Japan, vol. 44, no. 2, pp. 158–161.
-
Interview with Living Robot Inc.
リビングロボットに訊く!「あるくメカトロウィーゴ」と歩む未来
Shun Nagaoka, Shunya Tadano, Shinya Tajima, and Yuto Kemmotsu
Journal of the Robotics Society of Japan, vol. 43, no. 4, pp. 391–397.
-
Interview with Koei Dream Works, Ltd.
株式会社弘栄ドリームワークス 最先端配管点検ロボット「配管くん」の秘密に迫る
Yuto Kemmotsu, Shunya Tadano, Shun Nagaoka, and Kohei Yamamoto
Journal of the Robotics Society of Japan, vol. 42, no. 6, pp. 543–547.
Background
Education
-
PhD Student
2025—PresentDepartment of Robotics, Graduate School of Engineering, Tohoku University
Research: social navigation and pedestrian trajectory prediction
-
Master of Engineering
2023—2025Tohoku University
Thesis: Pedestrian Trajectory Prediction Considering Visual Attention and Behavioral Uncertainty
-
Bachelor of Engineering
2019—2023Iwate University
Thesis: Knife Operation Support System for Hemiplegic Patients Using Skeleton Estimation
Career
-
Visiting Scholar, Robotics Institute, University of Technology Sydney
Mar 2026—Nov 2026 -
Graduate Program for Integration of Mechanical Systems (GP-Mech)
Apr 2024—PresentTohoku University
Awards
-
Outstanding Presentation Award
Dec 2025System Integration Division Conference 2025, SICE
Dynamic Costmap Adjustment for Autonomous Mobile Robots Considering Smartphone-Distracted Pedestrians
-
First Prize
Sep 2024Boeing University Externship Summer Seminar 2024
Japan-WIDE Sustainable Aviation Fuel and its Infrastructure Development
-
National Runner Up
Sep 2024James Dyson Award 2024
ARALA — Additive Robotic Attachment for Lab Automation